Overview Link to heading
A data-driven project that models long-term postoperative weight trajectories after bariatric surgery and translates these patterns into clinically interpretable, patient-level predictions.
Project Details Link to heading
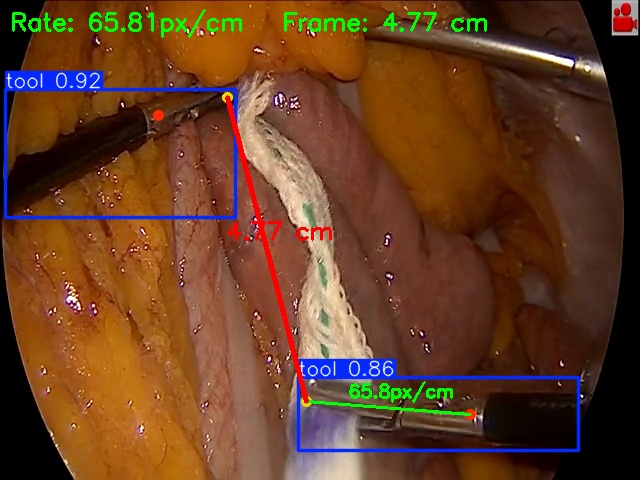
In gastric bypass surgery, biliopancreatic limb length is a key technical variable that influences metabolic outcomes and nutrition-related complications. Despite this, limb length is commonly estimated visually, a subjective practice that varies widely between surgeons. This project addressed whether a measurement-oriented computer vision system could provide accurate and reproducible intraoperative length estimates.
I developed and evaluated a YOLOv11-based pose estimation pipeline that detects laparoscopic instruments, estimates their spatial pose, and computes calibrated inter-instrument distances using an in-scene reference segment on the grasper tip. The system converts pixel distances into real-world centimeters without requiring external tracking hardware.
Two model variants (YOLOv11M and YOLOv11L) were trained and benchmarked on annotated laparoscopic video frames adapted from a public dataset. Performance was assessed using COCO detection and pose metrics, with additional agreement analyses comparing computer vision–derived measurements to surgeon estimates and to ruler-based ground truth.
The results showed strong detection and pose performance, with YOLOv11M achieving higher precision and fewer false positives, making it more suitable for safety-critical intraoperative workflows. Surgeon visual estimates demonstrated a consistent bias and wide limits of agreement relative to the computer vision measurements, highlighting the limitations of fixed visual estimation. External validation using a sterile ruler confirmed that the system could recover real-world distances with minimal error.
This study demonstrates the feasibility of objective, calibrated intraoperative limb-length measurement using computer vision and outlines the technical requirements for real-time deployment in bariatric surgery. A manuscript describing this work is currently under review.
A manuscript describing this work is currently under review.